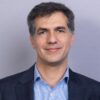
Giorgio VALMORBIDA
I am a Professor at L2S, CentraleSupelec, and member of the team Inria-DISCO Gif-sur-Yvette, France. I completed my Ph.D. in 2010 at LAAS/CNRS at Toulouse, funded by the Programme Alban, in the group MAC (Méthodes et Algorithmes en Commande). My thesis focused on developing methods based on convex optimization and polynomial programming for the stability analysis and controller synthesis of polynomial systems and systems with input constraints. From 2010 to 2012, I was Assegnista di Ricerca' with the Dipartimento di Ingegneria di Sistemi e Produzione at the University of Rome Tor Vergata. From 2013 to 2015, I was Post-Doctoral Research Assistant at the Control Group, Engineering Department, University of Oxford, Oxford, UK. From 2013 to 2015, I was a Fulford Junior Research Fellow at Somerville College, University of Oxford, Oxford, UK. I obtained my "Habilitation à Diriger des Recherches" at University Paris-Saclay in 2021. / CentraleSupélec
giorgio.valmorbida@l2s.centralesupelec.fr
L2S, CentraleSupélec
3 rue Joliot Curie
91190 Gif-sur-Yvette, France
Nonlinear Model Recovery Anti-Windup Control of Non-Salient Pole Permanent Magnet Synchronous Motor
Design of low-dimensional controllers for high-dimensional systems
Global Asymptotic Stability Certificates for Discrete-Time Lur’e Systems Under Incremental-Like Restrictions
Using Ramp Functions to solve LP-based MPC
Output-feedback controllers with guaranteed L 2 -gain for continuous-time Lur'e systems using noncausal Zames–Falb multipliers
Verification Methods for the Lyapunov–Krasovskii Functional Inequalities
Regional Stability Analysis of Discrete-Time Piecewise Affine Systems
Controller Design for Constrained Discrete-Time Uncertain Linear Systems Using Implicit Functions
Necessary stability conditions for reaction-diffusion-ODE systems
Exponential Stability of Continuous-Time Piecewise Affine Systems
Global Stability Analysis with Piecewise Quadratic Lyapunov Functions for Positive Discrete-Time Linear Systems Subject to Saturation in Actuators
Análise de estabilidade robusta de sistemas lineares incertos utilizando o critério de Liénard-Chipart
Mapping back and forth between model predictive control and neural networks
Stability analysis of Lure systems under aperiodic sampled‐data control
Quadratic programming with ramp functions and fast online QP-MPC solutions
Linear assistance filter design for electric power steering systems with improved delay margin
An implicit representation for the analysis of piecewise affine discrete-time systems
Generalised Lyapunov functions for discrete-time Lurie systems with slope-restricted nonlinearities
Stability Analysis of a Class of Discontinuous Discrete-Time Systems
Solving LP-MPC problems using ramp functions
Robust stability analysis of continuous PWA systems
Output feedback control of discrete-time Lur'e systems through FIR Zames-Falb multipliers
Stability properties for two coupled reaction-diffusion equations
Design of Saturating State-Feedback with Sign-Indefinite Quadratic Forms
Control design of uncertain discrete‐time Lur'e systems with sector and slope bounded nonlinearities
Event-triggered control for discrete-time piecewise affine systems
A Steer-by-Wire Control Architecture Robust to High Assistance Gains and Large Transmission Delays
Dynamic output-feedback control of continuous-time Lur'e systems using Zames-Falb multipliers by means of an LMI-based algorithm
Lyapunov Function computation for Periodic Linear Hybrid Systems via Handelman, Polya and SoS approaches: A comparative study
Accounting for Constraints in Delay Systems
Advances in Distributed Parameter Systems
Analysis of Linear Partial Differential Equations Using Convex Optimization
Estabilidade Regional de Sistemas Lineares de Tempo Discreto sob Saturação de Controle Assimétrica
State-feedback design for nonlinear saturating systems
An LMI Approach for Stability Analysis and Output-Feedback Stabilization of Discrete-Time Lur’e Systems Using Zames-Falb Multipliers
Stabilization of sampled-data Lure systems with slope-restricted nonlinearities
Stabilization of Discrete-Time Piecewise Affine Systems in Implicit Representation
Optimal Sensor Placement for Partially Known Power System Dynamic Estimation
Control for autonomous vehicles in high dynamics maneuvers : LPV modeling and static feedback controller
Self-scheduled $H_\infty$ control of autonomous vehicle in collision avoidance maneuvers
An LMI-based iterative algorithm for state and output feedback stabilization of discrete-time Lur’e systems
On Quantization in Discrete-Time Control Systems: Stability Analysis of Ternary Controllers
Stability of Sampled-Data Control for Lurie Systems with Slope-Restricted Nonlinearities
Estabilização quadrática por realimentação de saída de sistemas Lur'e a tempo contínuo via LMIs
A geometric stabilization of planar switched systems
Stability analysis of piecewise affine discrete-time systems
Regional Stability of Discrete-Time Linear Systems Subject to Asymmetric Input Saturation
Design and Flight Experiments of a Tube-Based Model Predictive Controller for the AR.Drone 2.0 Quadrotor
Delays and Interconnections: Methodology, Algorithms and Applications

CentraleSupélec,
3, rue Joliot Curie,
91190 Gif-sur-Yvette
Supporting institutes

©2026 L2S - All rights reserved, reproduction prohibited.
